The entire series of this topic has 8 blogs:
Use Fixed RPM With Wide Rotor As Power Surge Mechanical Capacitor
| 250 grams Takeoff |
HD Video | 30 minutes Endurance |
Sustained Vertical Dive |
|
| DJI Mini Pro | ❌ | ✅ | ✅ | ❌ |
| DJI Mini Without Phone | ✅ | ❌ | ✅ | ❌ |
| DJI Mini With Phone App | ✅ | ✅ | ❌ | ❌ |
| DJI Neo | ✅ | ✅ | ❌ | diffi-culties |
| DJI Avata | ❌ | ✅ | ❌ | ✅ |
| Flywoo LR4 With Lipo | ✅ | ✅ | ❌ | ✅ |
| Mayfly V2.0 | ✅ | ❌ | ✅ | (no test) |
| Flywoo LR4 With Li-Ion | ❌ | ✅ | ✅ | diffi-culties |
| ⭐Converged AIoT | ✅ | ✅ | ✅ | ✅ |
|
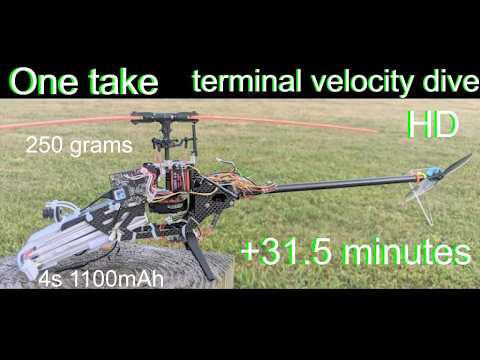
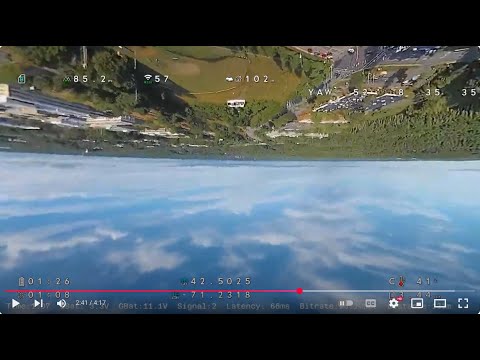
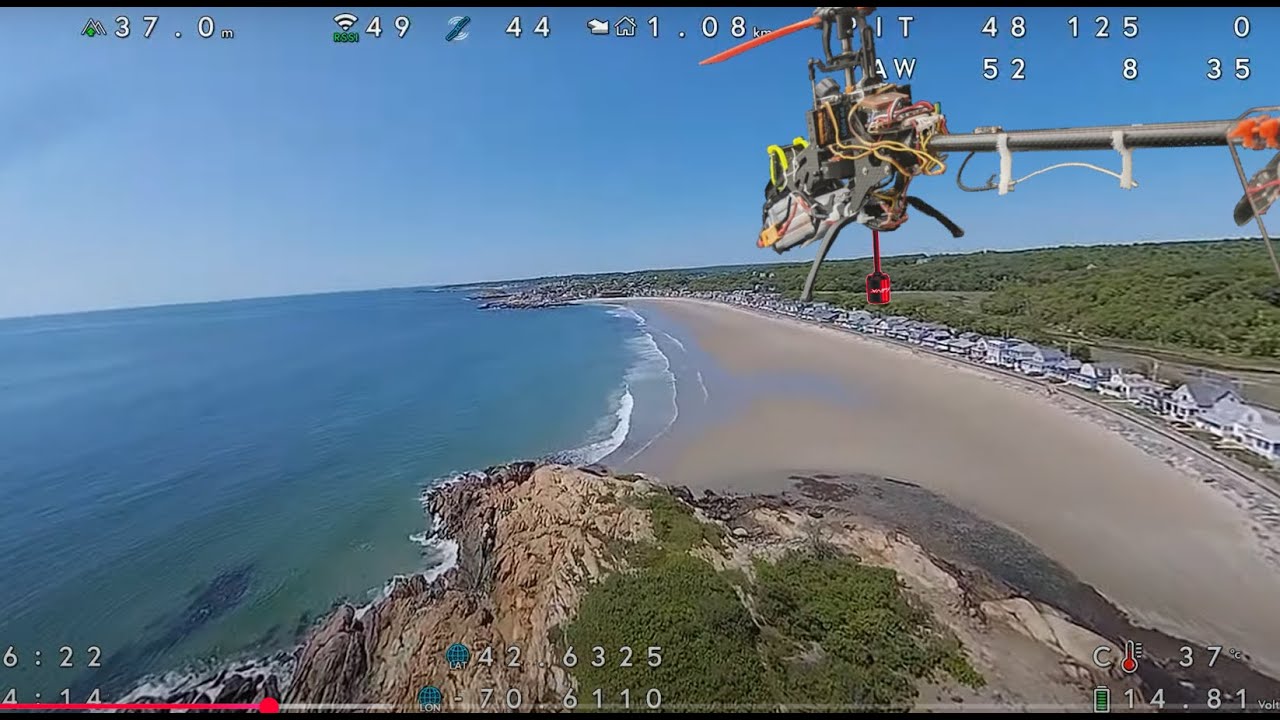
The helicopter's wide rotor acts as a flywheel during power
surges and high-G maneuvers. In the video on the right, the
same build (and the same battery pack) was subjected to a
terminal-velocity dive punch-out at 2:39, and there is no
visual difference between this punch-out and the extreme
robotics build's punch-out with a "120C"- marked battery.


Use Popular Hand-Held Electronics Cells For Their Lightweight And Low-C-Cutoff-Protection
Moderate C-Rated batteries are "low-C" by the hobby industry
due to marketing pressure. According to the US Department of
Energy,
https://www.energy.gov/eere/vehicles/articles/reducing-reliance-cobalt-lithium-ion-batteries,
the leading lithium-cobalt battery for passenger cars has a
nominal energy density of 190 Wh/kg, with reasonably
thin-layered electrode construction at a moderate discharging
rating, and reserving 10% electrode to prevent damage, equating
to 190 Wh/kg x 90% = 170 Wh/kg. We use airsoft gun batteries,
as the device is optimized for lightweight. And the frequent
product updates utilize the latest battery technology. The
half-hour endurance video with 4S 1.1 Ah cells has 3.55 V x 4 x
1.1 Ah = 15.6 Wh with an energy density of 15.6 Wh / 0.0919 kg
= 170 Wh/kg, matching the leading car battery chemistry.
|
1st discharge, forced landing. 1st recharge from about 3.5V per cell. Recharge 1105mah.

|
||
|
2nd discharge, forced landing. Video in the lowering RPM
discussion section, endurance 29 minutes. 2nd recharge from about 3.47-3.50V per cell. Recharge 1044mah.   |
||
3rd discharge video is 30-minute mission time in the
first section discussing 4 criteria.  3rd recharge from about 3.47 to 3.50V. Recharge 1028mah. |
||
4th discharge. Half discharge.
Half recharge. No pictures. |
||
|
5th discharge. Forced landing but at RPM3430 for racing
and shallow draining, not deep draining as forced landing
in RPM2670. Footage is the diving punch-out evidence of the first section of this chapter page. 5th recharge from about 3.62V. Recharge 824mah. 
|
||
6th discharge discussed in the lowering RPM section.
 6th recharge from 13.86V (3.47V per cell) 1103mah |
||
7th discharge. Forced landing but at RPM3430 for racing
and shallow draining, not deep draining as forced landing
in RPM2670.
 7th recharge from 14.15V (3.538V per cell) 1037mah fill |
||
8th discharge. Forced landing but at RPM3430 for racing
and shallow draining, not deep draining as forced landing
in RPM2670.
 8th recharge from 3.54V per cell 968mah fill |
||
9th discharge. Forced landing but at RPM3430 for racing
and shallow draining, not deep draining as forced landing
in RPM2670.
 9th recharge from 14.13V (3.533V per cell), 1041mah fill |
In contrast, the 95-C batteries with very low internal resistance have true cell voltages of 2.99-3.00V, nearly identical to the displayed 2.98V during force landings in the following test video, and hence the damage. This particular mission used a stipulated collective pitch limited to 8.2 degrees (OSD "throttle" 50) with production cusped airfoil blades.
 |
| https://www.youtube.com/watch?v=I5pFMTR3HM8 Messed up with https://archive.org/download/yt-I5pFMTR3HM8/yt-I5pFMTR3HM8.mp4 |
Off-The-Shelf Endurance Optimization Oxy2 193mm And Microheli 180mm Plastic Blades Interchangeable
The prototype endurance
build with Tattu1000(same as GensAce900) created
a calibration data point for the Oxy2 211mm (210
nominal) orange blades (479mm diameter) in the
manufacturer's spur propeller efficiency data set.
The following paragraphs figure out that the 479mm
diameter Oxy2 rotor is equivalent to a 13.8-inch spur
propeller.
|
|

T-Motor 4004's data is saved in https://drive.google.com/file/d/1u8NkHY28v4AklgQdXVgva0rvAXevIcff/ ,
T-Motor 2806's data is saved in https://drive.google.com/file/d/1A3C4TgKU-0X7GzRMv7PgJEgXHwu2BZ2c/ ,
Sunnysky 4004 400kv's data is saved in https://drive.google.com/file/d/1pYOJN9Hi-93svuun-8ODcXMY-UGgvON8/ ,
Sunnysky 4004 300kv's data is saved in https://drive.google.com/file/d/1xwbcVjCucTQAQFk8mq_o6eJbOfekKUEO/ ,
Sunnysky 2806 400kv's data is saved in https://drive.google.com/file/d/1MKCFu733HeZotZHhqp3N-I6adnCU65xG/ ,
Sunnysky 2806 650kv's data is saved in https://drive.google.com/file/d/1xpaYDaShMJg4fl07ka_vFqt4RPkkexjF/ ,
T-Motor 2306 1500kv's data is saved in https://drive.google.com/file/d/10ZCGP450bEhaZmFgvNeRTqEayQL3zlYq
HGLRC 1303.5's data is saved in https://drive.google.com/file/d/1F2D4R6p1V8eqaQ5DHQGh-GXK_b36V62K/ ,
SParkhobby 1303.5's data is saved in https://drive.google.com/file/d/1ceFDKYo8B5uGcjp6UcM5C6dPKCF6AHe9 ,

https://docs.google.com/spreadsheets/d/e/2PACX-1vSpiShuV8YVVwZKwM-ojjlyORqC0YDGnzCaL5DzYb-wkyQWhiVmK5UHBmh_2f_qZVj2UNrPEmyAW1oq/pubhtml?gid=0&single=true&widget=true&headers=false
 https://docs.google.com/spreadsheets/d/e/2PACX-1vSpiShuV8YVVwZKwM-ojjlyORqC0YDGnzCaL5DzYb-wkyQWhiVmK5UHBmh_2f_qZVj2UNrPEmyAW1oq/pubhtml?gid=980800723&single=true&widget=true&headers=false

 https://docs.google.com/spreadsheets/d/e/2PACX-1vSpiShuV8YVVwZKwM-ojjlyORqC0YDGnzCaL5DzYb-wkyQWhiVmK5UHBmh_2f_qZVj2UNrPEmyAW1oq/pubhtml?gid=1539325005&single=true&widget=true&headers=false
https://docs.google.com/spreadsheets/d/e/2PACX-1vSpiShuV8YVVwZKwM-ojjlyORqC0YDGnzCaL5DzYb-wkyQWhiVmK5UHBmh_2f_qZVj2UNrPEmyAW1oq/pubhtml?gid=278578110&single=true&widget=true&headers=false
Our prototype rotor's efficiency is equivalent to
the 13.8-inch drone propeller's efficiency in terms
of the same torque, RPM, mechanical, and electrical
efficiency, according to above efficiency charts
and the following RPM chart.

So, the question is how to shift the prototype 4004-motor-13.8-inch-prop combination and scale the rotor blade toward an overall more efficient craft, not just an efficient rotor, according to the efficiency trend curve.
It is well known that disk loading (when represented by
rotor diameter) is inversely proportional to the
efficiency (when represented by grams per watt) of
lifting power consumption in a optimum region.
So, the Python code of calculating the efficiency of
the most efficient motor-propeller combinations for a
249-gram lifting force to fit all manufacturer and
experimental data is:
lifting_weight_per_watt =
14.7 * (propeller_span_x/13.8);
This formula's propeller_span_x is for blades with
twisted and curved edges. This formula can be applied
to slightly heavier motors. For example, the 4004 kv300
motor has a best-efficiency conservative estimate of 17
g/W for a 250 g lifting force, according to the curve.
And the matching blade span width is 17 =
14.7*(x/13.8), x=16 inches, which is close to the
highest-efficiency curve for the 4004 300kv motor.
The generalized formula is applicable to slightly
lighter (near the optimum region), smaller motors, such
as the T-Motor AS2306 1500kV at 8.3 g/W efficiency and
an 8- to 9-inch propeller. 14.7 × 8.5 in / 13.8 = 9.1
g/W, which is close to the manufacturer's published
efficiency of 8.3 g/W. For the HGLRC 1303.5 motor, the
formula gives 14.7 × 3.67/13.8 = 3.9 g/W, which is also
close to the manufacturer's published data.

The Python code for the calculation is
mass_without_propeller_motor_battery = 111.0; #grams; change it for a particulr craft constructions's endurance curve
propeller_diameter = 13.8; #inches; change it to slide the rotor width x-axis in a endurance curve
motor_plus_propeller_mass = 62.5 * (propeller_diameter/13.8)**1.5; # grams
battery_cells_mass = 249.0 - mass_without_propeller_motor_battery - motor_plus_propeller_mass; # grams
battery_energy = 0.171 * battery_cells_mass; # watt-hours
lifting_force_per_watt = 14.7 * propeller_diameter/13.8; # grams
power_tran_power_consume_rate = 249.0 / lifting_force_per_watt; # watts
total_craft_power_consume_rate = power_tran_power_consume_rate + 5.2; # watts
endurance = battery_energy / total_craft_power_consume_rate * 60.0; # minutes
print (endurance);
The motor and propeller combined mass can be calculated by the Python3 code:
motor_plus_propeller_mass
= 62.5 * (propeller_diameter/13.8)**1.5;
. This formula excludes the motor shaft and propeller hub.
The coefficient 62.5 is calibrated to the prototype build's
measurements, a 13.8-inch-equivalent propeller producing 35
minutes of endurance. This formula is suitable for slightly
larger and smaller motors. For example, the 4004 300 kV
motor weighs 50.5 grams (as shown in the substitution parts
chapter), while 16-inch drone propellers are about
18-21 grams (excluding the center hub) in the DJI Inspire
3. 62.5*(15/13.8)**1.5 = 70.8 grams = 50.5g + 20.3g. For
the DJI Mavic Pro motor at 24 grams (excluding the motor
power wires, excluding the motor shaft) with a pair of
5.3-gram, 8.3-inch propeller blades.
62.5*(8.3/13.8)**1.5=29g= 24g + 5.3g. For a 2306 motor with
an 8.3-inch prop as optimal, again, 62.5*(8.3/13.8)**1.5 =
29 g, very close to the actual available parts weight of
25g + 5.3 g = 30.1 g.
The 4 pictures of DJI Mavi pro parts weighing is
here.


| The picture of the T-Motor 2306 weighing is here. Trimming the extra fixture arms and removing the screws should reduce the weight to 25 grams. |

|

|
The motor closest to the optimal peak, which would need changing main shaft to 3mm, is this one. Data table credit: Dr Kiwi https://www.rcgroups.com/forums/showthread.php?376491-Hyperion-Z2209-32-and-Z2213-24-performance


After entering the Python3 code into the Google Gemini
prompt, it produced the endurance efficiency trend curve on
the right. Endurance can be improved by adjusting the
helicopter rotor span to match that of an 11.5-inch drone
propeller at the peak of the orange curve in the craft
construction. Unfortunately, the 2308 motors in the market
are maded for rugged outdoor builds, not F3P or indoor
weight-saving builds, as shown in the picture on the right,
which has 5.3 grams of dead weight. The 2806 KV400 motor
compromise from T-Motor, Sunnysky, or MAD Components fits
the motor mass data points on the endurance curve closest
to the theoretical optimum, and a 12-inch propeller is
closest to the 11.5-inch compromise.
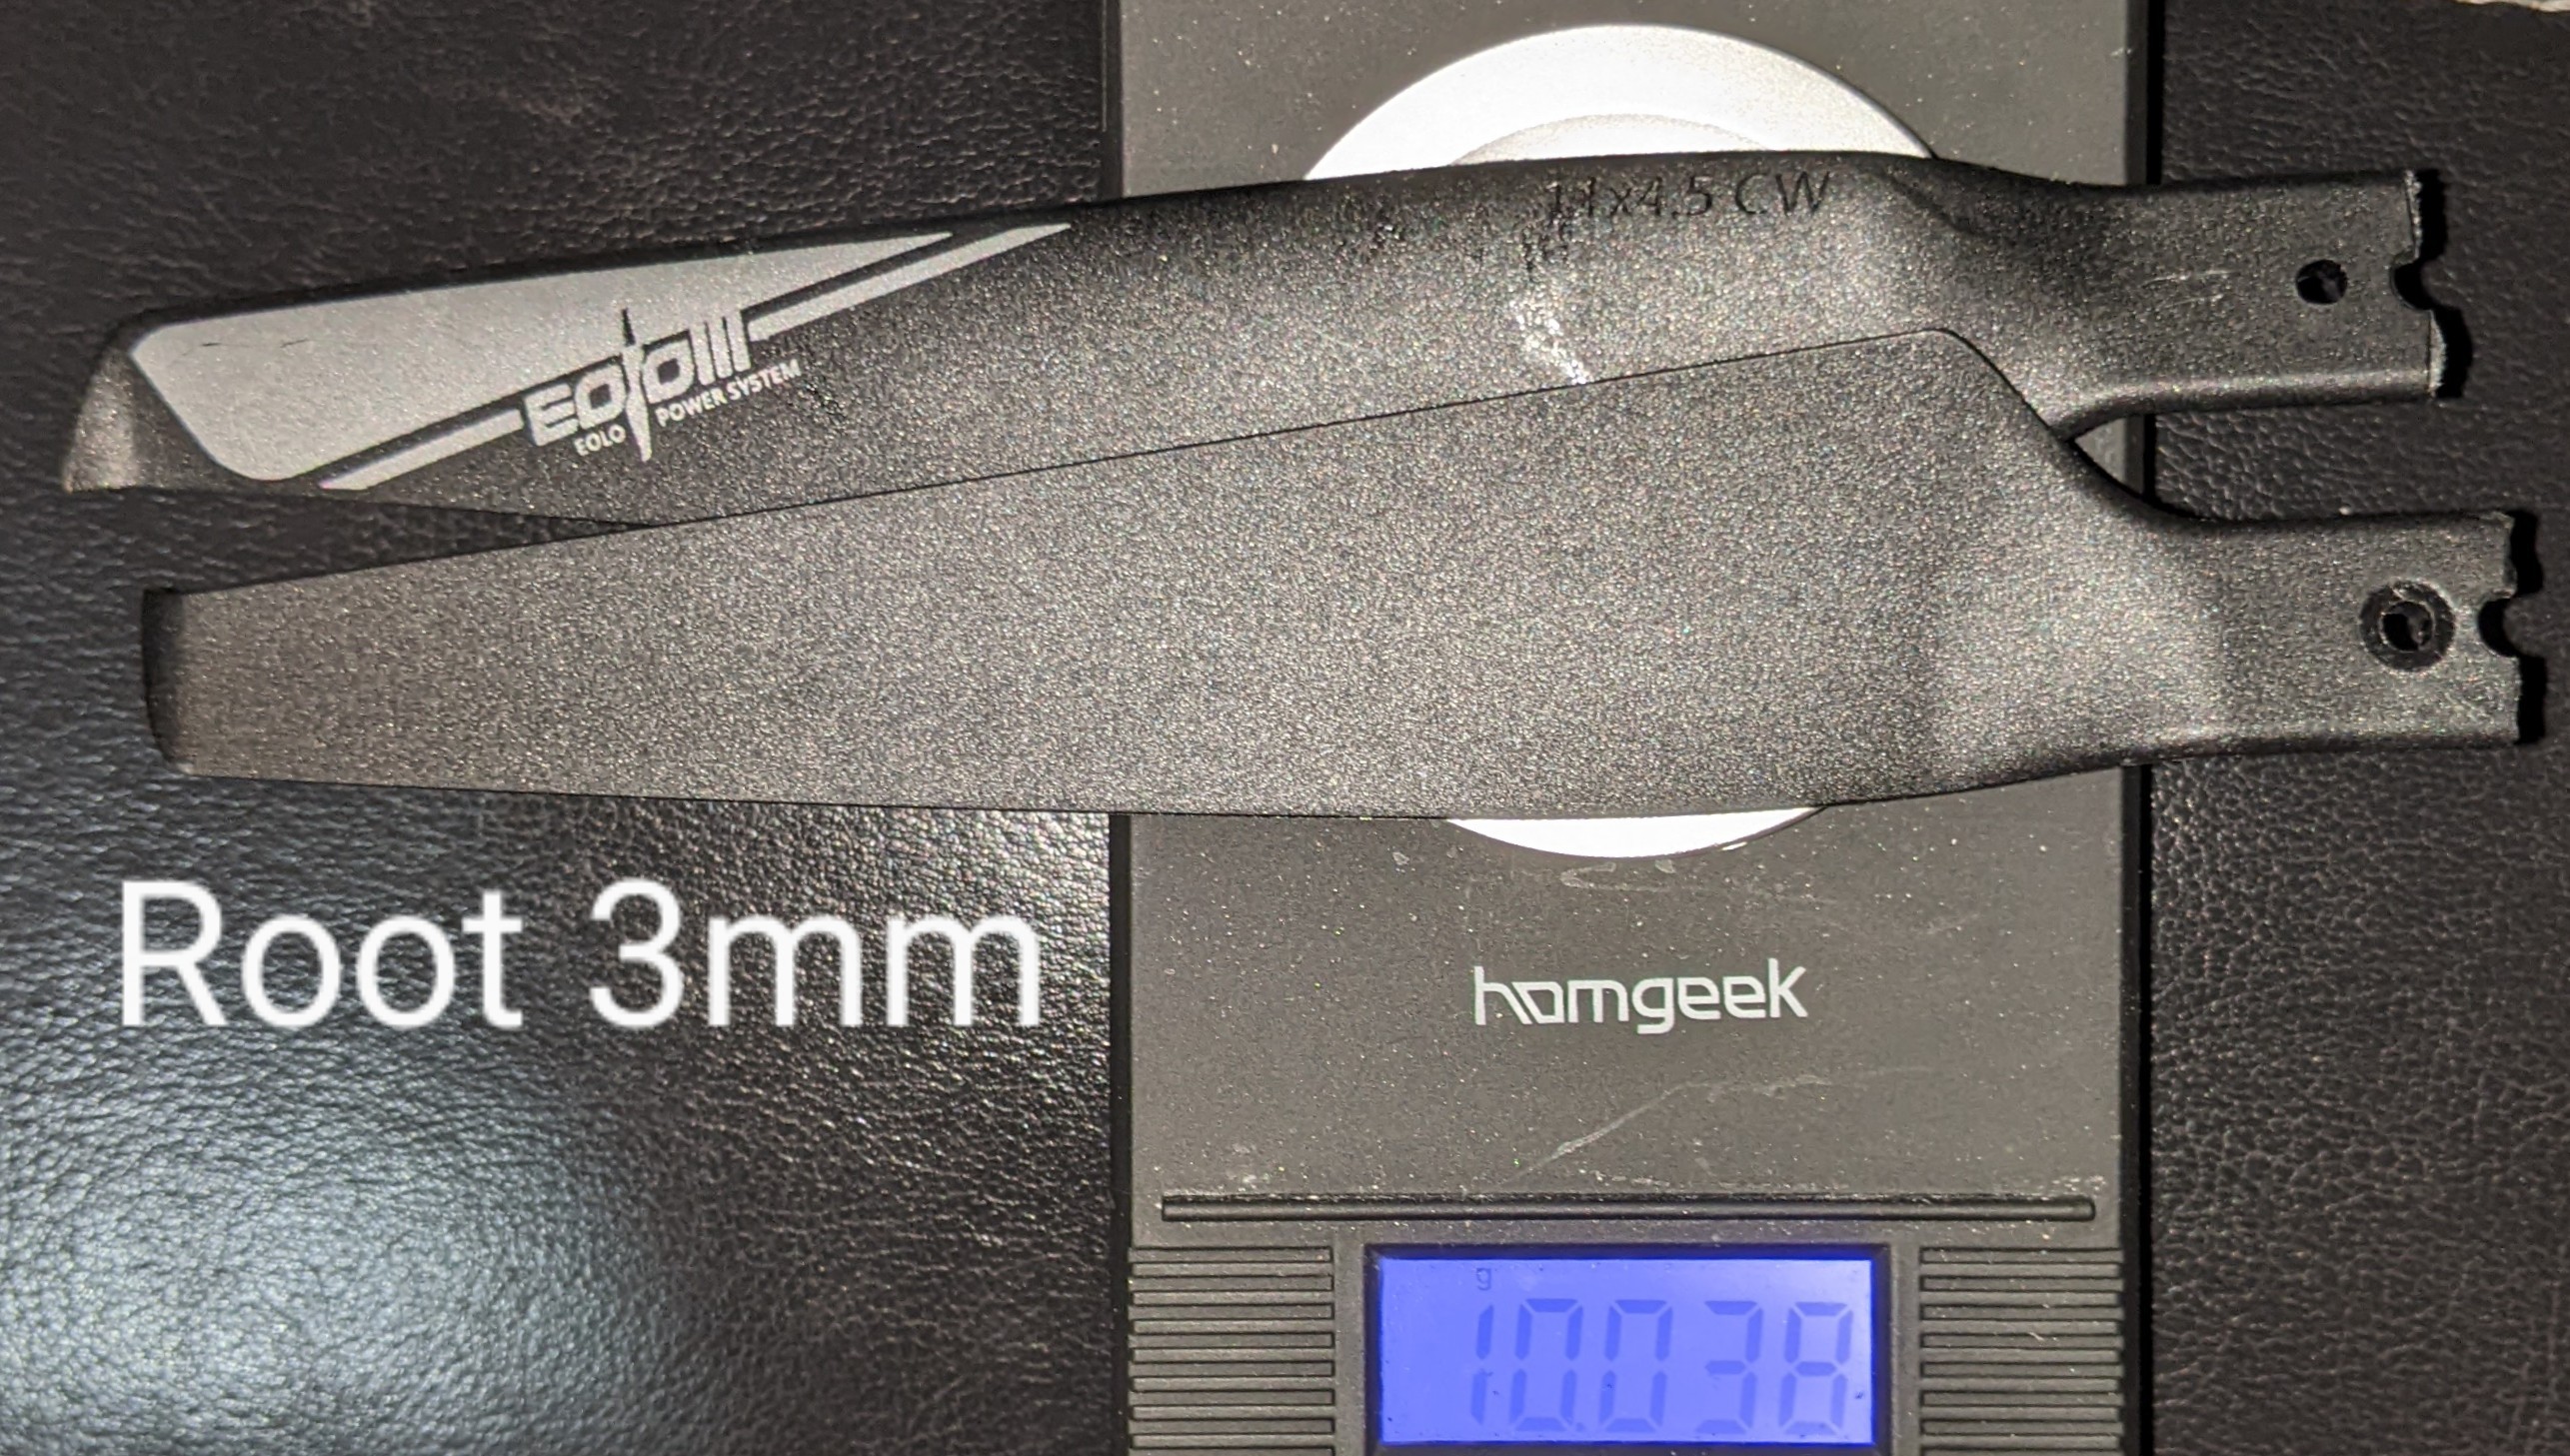
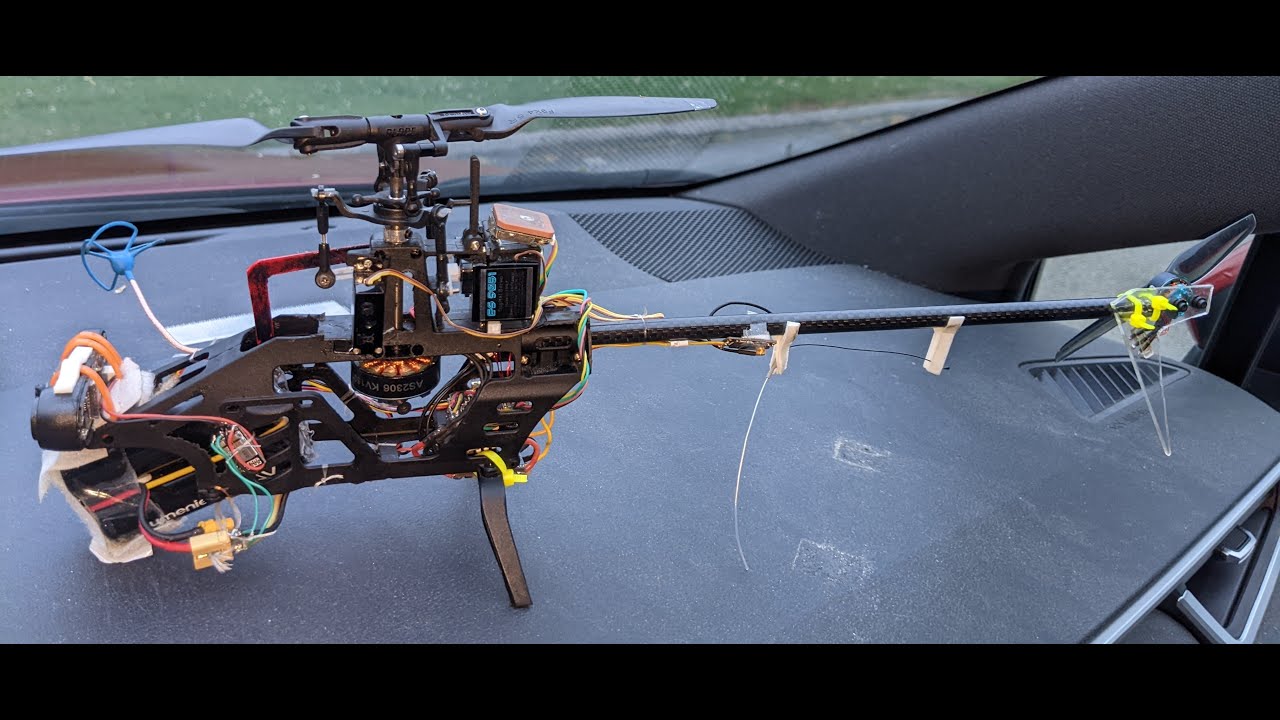
Unfortunately, attempting to use a 12-inch drone propeller with a twisted spurprop airfoil and a 2806 motor failed. The propeller has 249 grams of thrust, similar to the original endurance build with a straight, symmetrical airfoil, at 100RPM above the designated 3300RPM. However, the gyroscopic effect required for single-rotor mechanics is too weak to have stable craft control, so, as shown in the pictures below, large brass ballasts at 1mm thickness were added.

|

|

|
|


The twisted spurprop airfoil couldn't work even if tweaking
rotor diameter to slightly less than optimal to gain
gyroscopic effect and more optimized industry battery
construction in the next video because the relationship
between drag and attack angle is complex.

 |
| https://archive.org/download/yt-UzH81Z-O9o0/yt-UzH81Z-O9o0.mp4 |

The slanted Clark-Y airfoil, pictured on the right, also suffers from the complex correlation between drag and lift of the twisted spurprop airfoil. But what makes Clark-Y worse is that it is heavier than the straight, symmetrical prototype build. The advantage of the peak of the optimization curve by reduced blade and motor weights is largely canceled. In the picture on the right, you can see a flat surface of the blade root area, giving a fixed, designated angle of attack of the blade when the flat surface is level. At 3500 RPM, the 77 throttle (collective pitch) point is lower than needed to give the designated angle of attack. About 90 throttle points to make the flat surface level. And yet, the RPM is still low on giving adequate gyroscopic effect. And, when RPM is raised, and the angle of attack lowered further, motor overheating occurs because the Clark-Y airfoil has a larger drag than the operating drag when the angle of attack is lower than the designated angle.
TODO: Tungsten or uranium heavy material blades are the solution for the curved spurprop airfoil. The craft becomes a flying knife for a military strike in the operation notes.
The only option left is the straight symmetrical airfoil.
According to the NASA education page, the lift equation
is as pictured on the right. A is the airfoil area, V is
the airspeed, rho is air density, and Cl is the lift
coefficient. Division by 2 should be discarded because
our propeller has 2 blades that doubles the lift. Air
density is about 1.2 kg/m^3, V changes linearly with x
position of the propeller origin from the main shaft axis
with constant RPM 2640, angular speed 2640*2*pi/60 rad/s.
Area da is 0.018 blade width multiplied by dx. So, the
integration is for the quadratic of x from the axis
origin to the blade tip at 0.236 m. The simple polynomial
integration solution is the 3rd power of x multiplied by
a third of the constant. To generate 249 grams of lift,
the lift force equals 2.44 newtons. And according to the
dashed curve, the theoretical lift is much higher than
2.44 newtons. The section of the blade from the axis to
127 mm out should be considered zero-lifting because the
hub and bolts are not part of the airfoil out to 50 mm.
And between 50 mm to 127 mm, Reynold's number is too low
to produce lift, which can be felt as zero downwash when
tethered hover in hand. Between 200 mm to 236 mm, the
blade is blown downward with the wingtip vortex of the
previous sweeping of the blades. The green curve is the
corrected curve. The wing section between 200 mm to 236
mm from the origin axis out is considered non-lifting. At
the integration point of 200 mm, 0.2 m, the total lift is
the target of 2.44 newtons.
 The calculation points to the solution of improving
the fuel efficiency by a winglet to block vortex
turbulence. However, as tried in crafting the ballasts
for a 12-inch twisted spurprop airfoil, any substantial
winglet can only be safely made as an original factory
part, not as an after-market modification.

The overall compound power-tran efficiency has 2 peaks
with some systems, as shown in the video from SiieeFPV
channel, and we use the first peaks of motor-propeller
combinations for the highest efficiency (more than
double the fuel efficiency). The second hump may
be a motor construction oddity. It is often absent in
many motors, as seen in previous plots, and may not
have a mathematical interpretation.

The only practical solution for the endurance peak of 36
minutes is to use a 2806 motor running at 3300 RPM (according
to manufacturer data tables) with straight blades to simulate
an 11.5-inch twisted spur propeller setup's RPM and torque
(the purple curves in the second graph of this section). And
180 mm-long, 16 mm-wide blades approach the equivalent spur
propellers ((180mm*2+52)*0.732/25.4=11.9 inch), but will have
similar angular momentum to 13.3-gram blades as the prototype
build. The prototype build has an angular angular momentum of
1/12 x (14.6+5)/1000 x 0.473^2 x 2640/60*6.28 = 0.101, and
the practical solution has 1/12 x (13.3 + 5)/1000 x 0.410^2 x
3300/60*6.28 = 0.089. Mission time 31.5 minutes with
19 mm-wide blades. 19 mm width, instead of the ideal
16 mm, is another compromise.
Lowering RPM And Maintaining An Elevated Collective Pitch
The well-known rotor dynamics (not just for
helicopters) say that forward movement enhances lift.
RPM needs to be lowered for the endurance missions to
maintain the cruising blade attack angle at or higher
than the optimal in-place hovering attack angle,
avoiding the low efficiency of the lower attack
angle.
In the following two videos with substitute Oxy2 193mm
blades, for transition from prototype to production
build, the RPM was set at the cruising/loitering level
as in the original endurance build, and at 15% lower.
The original is on the left, and 15% lower RPM on the
right.
 |
| https://archive.org/download/yt-h_RNcwrsLwo/yt-h_RNcwrsLwo.mp4 |
 |
| https://archive.org/download/yt-PcCa3iTPCJM/yt-PcCa3iTPCJM.mp4 |
Still with the substitute Oxy2 193mm blades, the higher
attack angle of 6.7 degrees, used in the 6th cycle test
for the low-C battery testing section, gave even higher
fuel efficiency to reach 30.1 minutes mission time in
the video in the cycling
test section. In essence, the general operating
note's RPM setting table is meant for in-place hovering
efficiency at about 5 degrees alpha of the production
build blades and at about 6 degrees of alpha for
substitute Oxy2 193mm blades, not for endurance travels.
A potentiameter set point tuning knob lowers the RPM
set points by 5 in the prototype to the RPM 2500 regime
and by about 18 from 91 to about 73 in the production
build near RPM 2650 (before compensating for
temperature deviation from 50°F). The knob is
multiplexed into the throttle channel in the RF
control, pictured here. Notice that the -6 mark
compensates for the particular ESC's underclocking for
-9 points (97% underclocking).

|

|

|
The lowest point of adjustment is -19 points. Only
-17.7 of negative-19-to-positive-19 range was used in
the 30.1 minutes endurance mission to reach the
((-6)-17.7)*0.978=-23.2 LCD display point
23.2*1022/1000=-23.7 set point,
RPM 3270*(100-23.7)/(100-6)=2654 in the video.
This is because the throttle points are subject to the
scaling of 97.8% between 1022 and 1000 PWM, so
calculating RPM from PWM is cumbersome, and yet missing
ESC compensation. We, instead, use the set point to
start our calculation. Notice, at the video's test
temperature, the "normal" RPM is 3250*93/91=3321, so
the RPM is lowered by (3321-2650)/3321*100%=20% .
The modification of the RF control for endurance test
includes setting channel 1 curve to the CV4 of
hovering-cruising curve for the racing mode, setting RPM of
the racing mode to the same as the hovering-cruising mode
and with temperature and ESC compensation, all as pictured
above. And the endurace test is performed in the modified
racing mode to eliminate the accelerametor's perturbation
of the craft, which would have reduced endurance.
Battery Pack Build
From the optimized curve, our rotor diameter of 410 mm
corresponds to an 11.9-inch spur propeller diameter, as
previously calculated. Motor+propeller
weight 62.5*(11.9/13.8)**1.5=50 grams. Room for
battery cells is calculated at 249-111-50=88 grams with
the prototype craft construction. The production craft
construct is about 3 grams lighter, according to the
prototype build note,
compared to the prototype craft, excluding
motor/propeller/battery. We use GensAce1100 battery cells
of 87.2 grams within the budget.
Use cuticle scissors/cutter to remove old wiring of the
3S pack first. It is too hard to use a soldering
iron to clean the old wiring because the heat can damage
the cells, and working too fast can accidentally
short-circuit.
The rotary tool cutting disk is commonly made of
insulating ceramics, and we use it to cleave one cell at
the concave side so the cutter does not contact the
sealing side with the electrode tabs. The solder can have
work-related metallurgical hardening when the ceramic
cutter catches it and grinds it. You will feel the solder
tough to go through, and the cutter not contacting the
fiberglass board. When that happens, simply nick-pick out
the silver solder from the cutter's edge. Do not cleave
the cell tabs and then attempt to solder them because the
cobalt alloy does not weld with other metals, even with
specialty soldering fluxes such as aluminum flux.


 The front taping is a scaffolding and
can get in the way of the solder when performing point
jobs. In the picture here, you can see that the
terminal tab for the red wire is covered by tape. I
experienced a small short-circuit accident when I tried
to preserve the tape and maneuvered the solder into the
crannies to do the soldering job with only half the
tape sliver opened. The job was repeated and cleanly
executed with the front tape completely removed. A new
front tape was wrapped on after all soldering jobs to
the tabs were completed. This battery pack was used in
the 7-cycle test, which shows that the small
short-circuiting did not damage the cell.

The battery ceiling plate needs the outreaching curve trimmed at the injection mold line, as pictured here, and the bottom plate needs carving out a slope for the battery to slide into the bay. Both trimmings are required. The wedge of the battery is made with the truss as a guide while inserting foam mounting blocks.

Carbon Fiber Shaft Saves Weight
It saves
4.8-(1.8-0.1)=3.1 grams.
When using this carbon fiber shaft, the Kevlar insert
is 2 and a half strands. Using 3 strands resulted in
too tight a fit, resulting in a bent collar after
pulling out the shaft of the prototype motor, as
pictured below on the right with the tilted collar.
Also, 3 strands require very, very strong hands to
insert the shaft.


 With the production motor, the most
extreme case requires 7 strands of Kevlar insert,
as pictured on the right. When measured from the
rotor hub bolt hole to the bottom, the carbon fiber
main shaft is 3.5mm shorter than the original
build's titanium shaft. In the following picture,
the rotor hub bolt holes don't appear aligned, but
are correctly aligned at the upper (left) bore hole
on the 10 cm mark. The tape measure is concave, so
the heavier titanium shaft sinks to the bottom, and
the carbon fiber shaft is closer to the camera
lens. The camera lens is directly above the 18cm
mark, so the hub bolt-hole image is distorted in
the picture.
 When using the production Blade Fusion 180s fuselage, the shortened main shaft is not a problem because the v950 shaft is too long and needs to be trimmed at the bottom, and still has a 3mm protrusion. The carbon fiber shaft has the right length without excess protrusion. About 1 in 10 carbon fiber shaft sales has an off-center bolt-boring manufacturing error, as shown in the picture comparison here. |

|
3.3 Volt Computing Needs A Dedicated Power Supply


 |
| https://archive.org/download/yt-JB9bXxSAsf8/yt-JB9bXxSAsf8.mp4 |
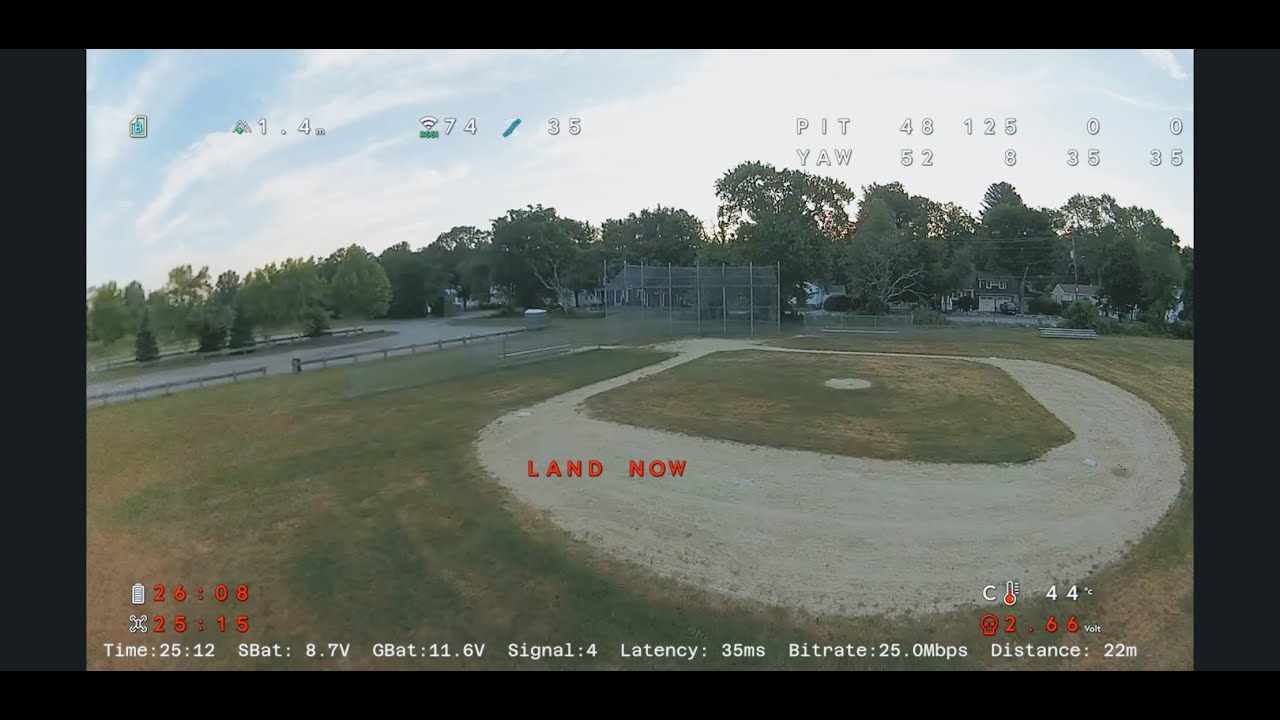
The solution is the "black 3.3v" buck converter and
setting the VTX radio transmission to 200 mW to
keep the current below 1.3 amp and voltage above
3.2 V.
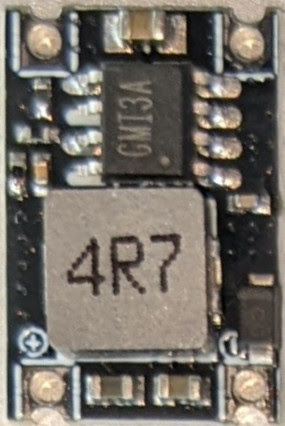


The buck converter's voltage will drop below 3.2V
and shut down the VTX when using 350(500) mW
radio output setting after arming the craft, and
the radio output setting takes effect. There are
several brands of buck converter of similar specs
that don't perform at the level of 1.3A x 3.2V =
4.16 W and shuts down VTX at a lower level. The
green buck converter on the right does not power
on the VTX at all. The Adafruid 3.3V 1.2A buck
converter can only power on the VTX in the
low-power, standby state. As soon as trying to
switch on the operation mode, even for the 25mW
mode, the converter shuts down the power. The
converter chip for the appropriate one has the
same DIN packaging across different batches with
different markings. The green converter products
have different packaging. The black converter is
verified as used by all 30-minute endurance
videos in this page. The substitute is to use the
9/10V output from the aviation computer board, as
pictured here.

DYS Sn20a And Favorite Blheli20a ESCs Interchangeable When Using Same Software And Configuration For Main Motor
DYS ESCs are rebranded as BladeThrust; Favorite ESCs
are rebranded as Lumeneir.
With the same BLHeli v14.9 motor software and startup
configuration, the Favorite 20A is interchangeable with
the production-build Thrust(DYS) sn20a ESC. They
require the same PID gains and the same 1.25 startup
power. However, when using DYS original BLHeli software
version 14.9, the BladeThrust has either battery
shorting (danger!) or MOSFET burnout (danger!) within a
few working cycles. So, the production parts listing
uses FVT.
Here's an audio recording of the same motor behavior
with the same error configuration (0.5 startup
power).
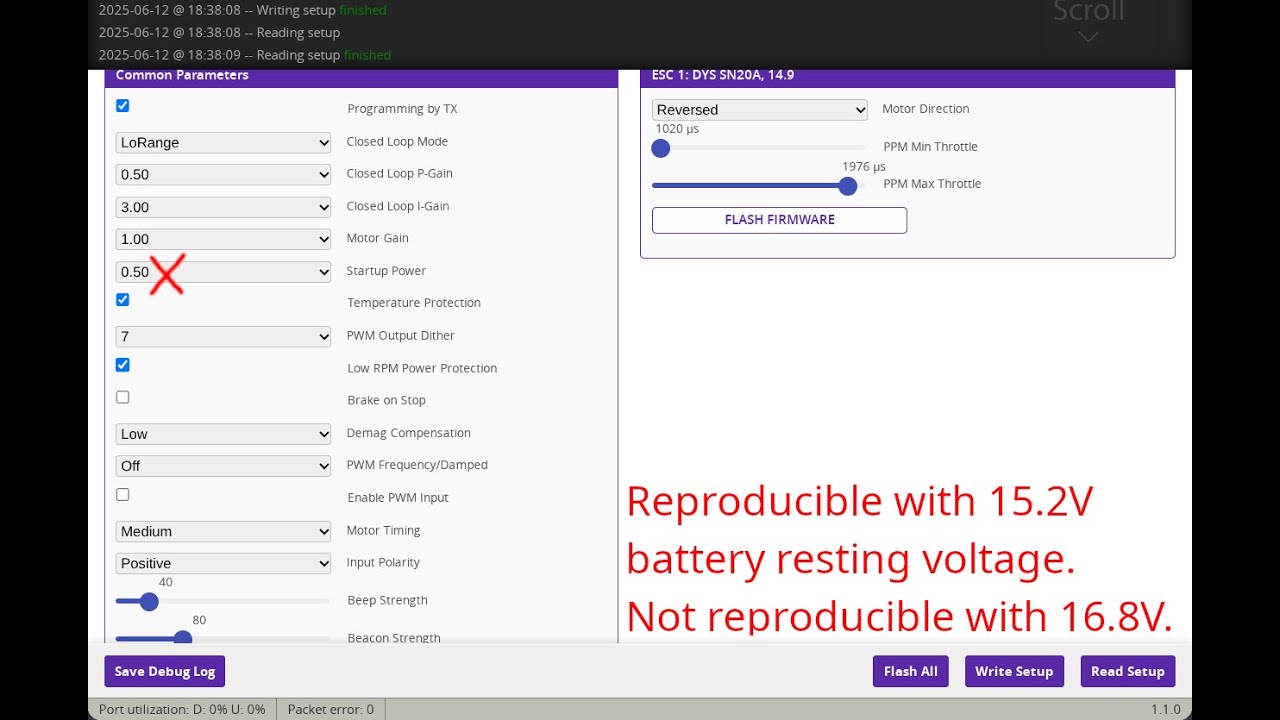 |
| https://archive.org/download/yt-DzV7GkrHKYQ/yt-DzV7GkrHKYQ.mp4 |
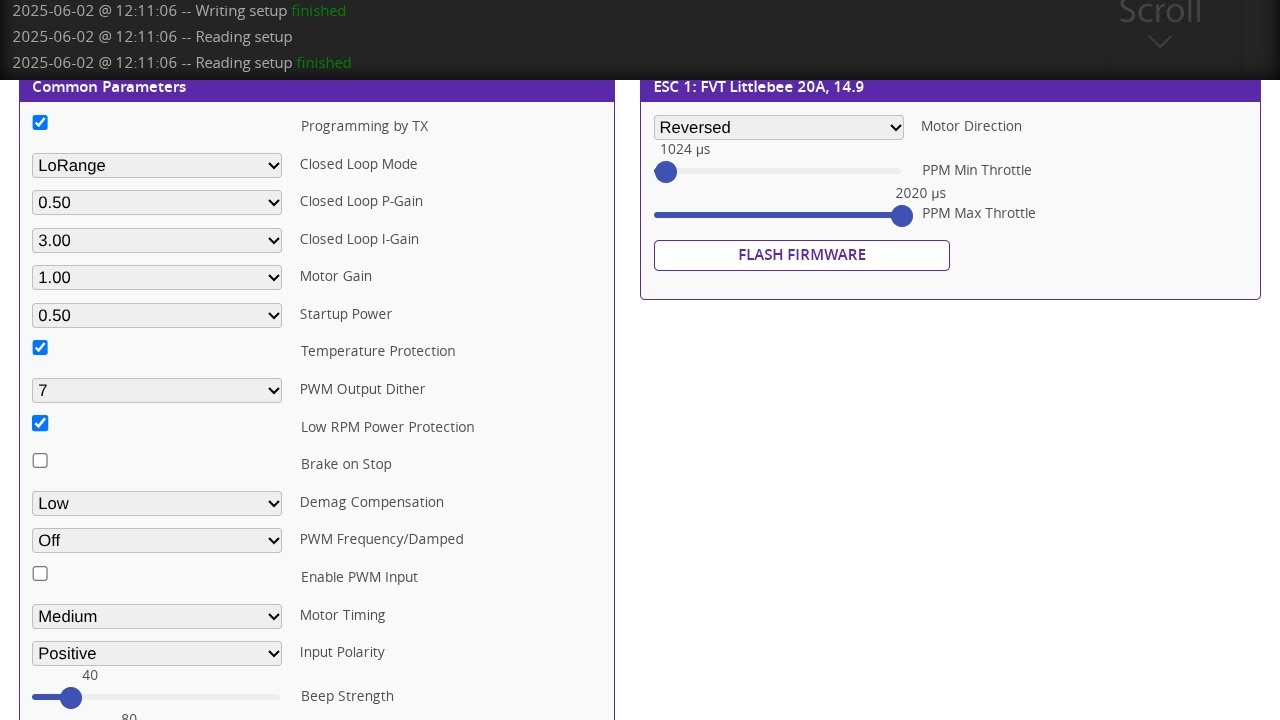 |
| https://archive.org/download/yt-z9Efeaixk0U/yt-z9Efeaixk0U.mp4 |
 |
| https://archive.org/download/yt-dL72Br5WKHw/yt-dL72Br5WKHw.mp4 |
 |
| https://archive.org/download/yt-yEqV_jt1wIw/yt-yEqV_jt1wIw.mp4 |
From left to right, DYS 16A, LittleBee 20A, Blade
Thrust 20A.


The ESC build is modified from the original AIoT build
with all stranded 20AWG wires replaced with lighter
solid 24AWG enameled wires to save 2 and a half grams.
The solid wires have slightly larger equivalent cross
section when the gauge numbers are the same, so the
solid wires can have a slightly larger gauge
number.
The 16 Amp BlHeli products earlier than year 2016 are
not to be used because either the dampening can not
be disabled or PI loop not available.


20 Amp BlHeli ESCs in the market don't have such
problem. Further more, all 20 Amp and 16 Amp BlHeli
(not BlHeli_s nor BlHeli_32) have the exact same
weight as shown in the above weighing. Blade
Thrust brand has navy blue PCB, DYS uses green, and
LittleBee uses black. BlHeli_s or BlHeli_32 are not
suitable because neither has the PI loop to provide
constant stable RPMs.
Soldering temperature should be standard 300 degrees
for ESC jobs. When accidentally dialed the
temperature to 350, it resulted in melting the MOSFET
components as pictured here on the left.
For the tail motor, in theory, the 3S 6A ESC can save
another 0.9 grams as shown in the picture on the right,
but this alternative can only function properly when
maneuver is small and smooth. The startup power with 3S
is too weak even though the output of the 6A ESC is
adequate, as the video below on the left. And this
problem persists even after startup boosting is changed
to maximum in the ESC's configuration.

 |
| https://archive.org/download/yt-MOT67_5bWFY/yt-MOT67_5bWFY.mp4 |
Interchangeable Oxy2 193mm Blades
The Align250 grips can be
stretched slightly to accommodate Oxy 193 mm
blades' root. The stretched grips holding the
blades are considered the standard gripping
strength of our production build. But when
using Blade 180 (either CFX or Fusion), they
need to be thinned using a Lego planning sled,
as shown in the following pictures. The
router's sled is made of 2 long, thin Lego
bricks CA glued to the front plate of the
rotary cutting tool. The Hypertough cutting
bit, when installed firmly to the end of the
rotary tool's chuck, incidentally makes the
proper thinning. The bumps of the bricks have
gaps smaller than the long sled's width, so
that the cravices never catch the
sled.


The Lego
flat top is well known to give a height increase
of about 1.5mm on top of the bumps of bricks. If
the cutting bit's shank length is not proper, or
if the bricks are augmented with a flat top, the
cutting bit needs to be augmented.


The
thin flat Lego brick that the blades are glued on
can be reused after scraping the glue
off.
The
final assembly, as tested in the "stock rotor"
video, was without the hub-grip-gap washer
because a test with the stock washer proved it
too tight (with tactile movement during
rotation).
T-Motor MN4004 And MN2806 400kv Prototype And Substitute Motors - 42 And 48 Grams Respectively
To prepare the motor for gear-less direct drive,
first remove the setscrew(s) of the shaft and
clamp the shaft down with a wrench socket spacing
beneath the motor bell until the shaft is flush
with the motor's top plane. Use a 1/2-inch wrench
socket with the 4004 motors. Then, CA-glue a #6
flat-head 1/2 inch machine screw as a pusher on
the clamp. Clamp the shaft down the second time
with the push rod assembly, as shown in the
picture, to remove the stock shaft of the motor.
The main shaft is not pressure-fit to the motor
but slightly thinner than the original motor
shaft. The video here shows that the short bell
shaft hole amplifies the thinned diameter,
resulting in wobbling.


Interchangeable Microheli 180mm Blades With NACA0012 Airfoil
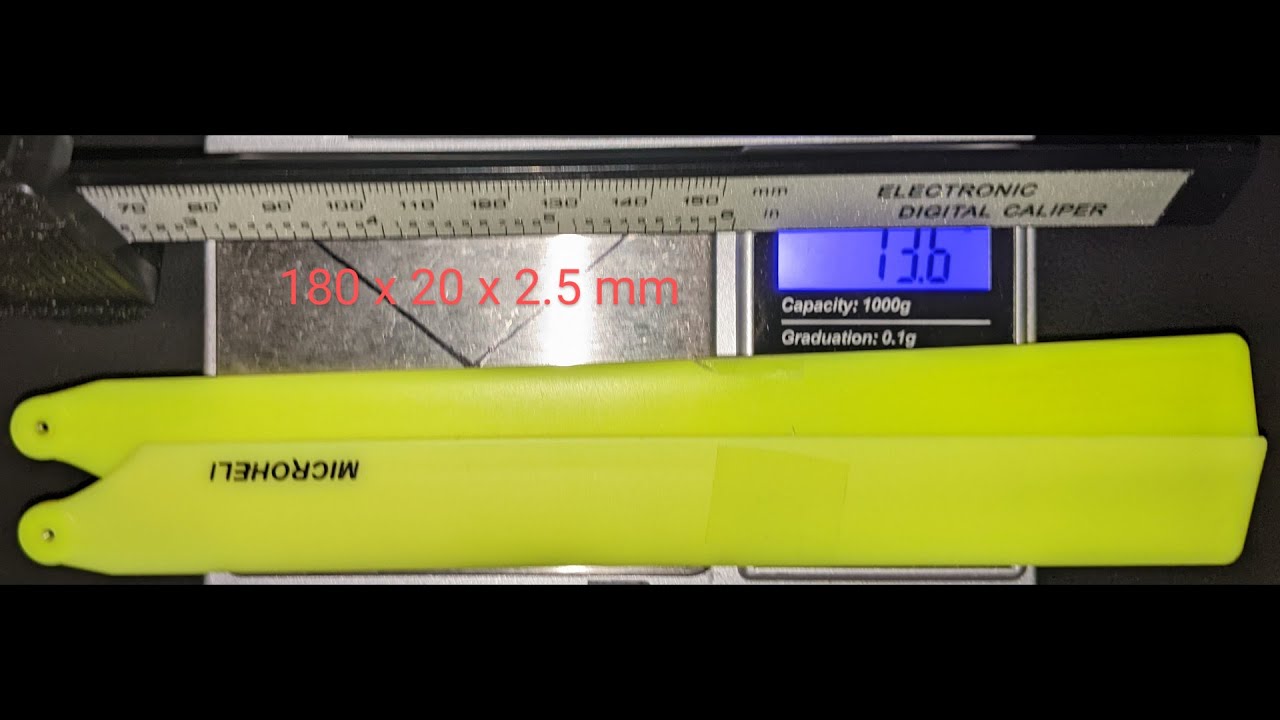
A pair weighs between 13.4g to 13.6g. Worst case
13.6g. Endurance of 30+ minutes verified here.
 |
| https://archive.org/download/yt-wo_Xr_omI4U/yt-wo_Xr_omI4U.mp4 |
Endurance
of the substitute Oxy2 193mm blades is shown in the first
section discussion of helicopter gyroscopic physics, which
has nearly identical endurance for builds with 180mm blades,
as shown in the video discussion of Joukowsky 10.5 airfoil of the Converged
AIoT chapter, as
well as the video on the right with interchangeable NACA0012
blades.
Tail Weight Reduction Alternatives
The original Lynx Blade 230 tail boom is 255 mm
long. The replacement 8x7x500mm carbon fiber tube from
ebay xzw791 can produce 2 250mm booms. The weight of the
replacement is expected to be 4.8g x 250mm / 255mm = 4.7
grams. But the actual weighing has 17.6g / 4 = 4.4 grams. So,
the replacement has 0.4 grams weight reduction.

 Countless verifications show no differences
in mechanical characteristics and robustness.

 Countless verifications show no differences
in mechanical characteristics and robustness.
 |
|
Motor Stator Rotation Stopper M3 Setscrew 3-5 mm All Interchangeable
The set screw can be tightened after building from the top.
3mm setscrew often comes with 4004 motor bells. 4 mm appears
more secure by the look. However, it has been tested with
dozens of missions with 3 mm without checking the screw and
without any incidence of a loose screw. This is likely
because the stopper does not have a consistent direction to
loosen to.
Blade Fusion 180 Rotor Counterintuitively Adds Weight
This
picture here shows the assembly without the washer if
you zoom in to the rotor hub.

When using the Fusion 180 stock rotor, don't use Fusion
180 Smart's DFC link (BLH05805), as they are heavy and
easily bent, as shown in the picture below, weighing in
at 1.222 g. Instead, use 180 CFX-Trio follower DFC link
(aka "original Fusion 180" DFC link, aka
BLH3755+BLH3754). When the follower arm is used,
turn the servo arms 11 half turns (5.5 full turns) to
equalize the length to the production setup with the
Infusion 180 DFC links. Every half turn is 0.175 mm in
pitch length and is worth 17 us PWM. The weight gain
from production parts is (Fusion180 2.93 grips - 0.48
blade bolts + 0.53 blade bolts + 0.81 thrust + 0.89
radial + 1.01*2 + 1.4 hub) - (production 3.7 grips +
0.9 dfc + 0.8 dfc bolt + 1.4 hub) = 1.3 grams. The
Fusion 180 grips are about 0.5 grams heavier than
production Align grips when bearing and DFC boltings
are all included for both; the CFX-Trio follower DFC
links are about 0.7 grams heavier when excluding DFC
boltings on both.


The
180CFX follower DFC links are designed for a trio blade
system, so the phase shift is not aligned with a duo
blade system. Trim the phase shift with a cutting disk
as follows to get the correct
alignment.


The 1.6 mm blade and DFC bolting of Fusion 180
are often bent after a crash. The blade bolting bore
holes need to be enlarged by a 1.7mm drill bit, then
enlarged again by a 1.8mm drill bit. The DFC bolting
just needs generic M1.6 bolts replacement after each
crash.


When installing his substitute DFC link, use high
torque on generic M1.6 bolting with the bolting
stopped by a generic M1.6 washer (quarter mm thin,
not the given washer in the kit), and don't use CA
glue because it can stick to the rotating parts.
The biting of a generic zinc-color-coated M1.6
screw into the thread is never loose with high
torque installation. The generic M1.6 bolting
allows frequent replacement after any light crashes
because M1.6 is weak as expected.
Do not use the flanged washers that are 0.5 mm each
and compress the grommet, resulting in a bumpy
rotor. Remember, the gap is only 0.5 mm before a
rubber grommet that has a 0.25 mm convex. Do trim
the Blade 180 feathering shaft less than 0.5mm
total as pictured below on the right.


The bumpy rotor with flanged washers compressing
grommets is recorded here in videos.
 |
| https://archive.org/download/yt-J_gPFs0dXBo/yt-J_gPFs0dXBo.mp4 |
 |
| https://archive.org/download/yt-P94Z0Kc-rp4/yt-P94Z0Kc-rp4.mp4 |
The left side is raw video of the bumpy rotor with
flanged washers that PID moderation could not fix
between 1:21 and 1:26. The right side is the same
bumpy video, but post-stabilized.
Good result with trimming 0.4mm (total) without
flanged washers is here. Raw video below on the
left is much less bumpy between 0:34 and 0:39.
Post-stabilized video on the right.
 |
| https://archive.org/download/yt-aBSUimj1uak/yt-aBSUimj1uak.mp4 |
 |
| https://archive.org/download/yt-C9ZUKg7itdw/yt-C9ZUKg7itdw.mp4 |
The
true interchangeable Blade 180cfx rotor does not need
feathering shaft trimming and naturally has zero
slop. But the introduction chapter discussed that it
needs more research before mass adoption.
 An experiment on the
alternative Align250 carbon-fiber blades are
0.2 grams lighter than Oxy2 nylon blades, and
the blade root thickness fits the aluminum
Align250 grips. The Align250 aluminum
grips are incompatible with Oxy2 blades due to
the narrower jaw width.


Production Build Must Adhere To Parts Listing/Build Substitution Notes For Material Properties
 An experiment on the
alternative Align250 carbon-fiber blades are
0.2 grams lighter than Oxy2 nylon blades, and
the blade root thickness fits the aluminum
Align250 grips. The Align250 aluminum
grips are incompatible with Oxy2 blades due to
the narrower jaw width.
In the picture below on the left, the upper
blade has a pronounced sagging due to a
previous experimental test with Align aluminum
grip. In that experiment, the blade root was
sanded thinner, which softened the material
surface. A rapid pitch-up flip at 1:08 in the
video below on the right caused a tail strike.
Also, the test showed that generic translucent
18-lb zip ties in the tail are not strong
enough and break with the tail strike. The part
listing's zip tie is stronger than the generic
product's nominal tensile strength of 18
lb.

 |
| https://archive.org/download/yt-DGAZOudXkq0/yt-DGAZOudXkq0.mp4 |
The sagging and tail strike mean that the blade
surface should not be sanded to force
compatibility, only carved. And this also shows
that the production build's Hypertough zip ties
can not be replaced with generic zip ties of the
same nominal specifications.
TODO: Highly Experimental Li-Ion Batteries
The LG 2500mAh 20A HE2 is well known to be only
44.1 grams per cell (if the sticker is removed),
1.1 grams heavier than the current production
build's cell weight, which is trivial to solve. The
low 2S voltage needs the 650 kV motor pictured on
the right. Trim the lead wires to remove the extra
0.5 grams of stator weight from the 400 kV variant.
But the 2500mah Li-Ion cells provide no
significantly more energy than the current
production build: 2.5x2x3.4~=1.1x4x3.7. In
addition, the higher current with lower 2S voltage
generates more waste heat and will likely further
reduce mission endurance.


The experimental harness weighs 4.8 grams in the
above first two pictures.

Lumenier 3000mah cells weigh 96.7 - 4.8 = 91.9
grams. Usable capacity above the simple ESC
MOSFET gate deterioration voltage of 3V per cell
is about 2650mah. Estimated endurance is 31.5 *
(2*3.5*2630) / (4*3.7*1100) = 35.6 minutes. For
Favorite ESC (with gate bootstrap), 31.5 *
(2*3.4*2800) / (4*3.7*1100) = 36.8 minutes.


Molicel 3500mah 10A cells weigh 93.8
grams (6.6 grams heavier than current
production build) with one cell unwrapped.
Usable capacity above the simple ESC MOSFET
gate deterioration voltage of 3V per cell is
about 2650mah. Estimated endurance is 31.5 *
(2*3.5*2850) / (4*3.7*1100) = 38.6
minutes. For Favorite ESC (with gate
bootstrap), 31.5 * (2*3.4*3300) / (4*3.7*1100)
= 43.4 minutes.


Weight saving required: replacing the avionics
computer plus radio control receiver with HGLRC
Specter to save 1.6 grams; using the 0.5 gram
step-up/down regulator to power the avionics
computer's on the VIN to workaround the BAT
requirement of 8.4V minimum; removing the balance
wireset of 2.4 g and instead using a charging
jig; replacing the tail fin material with
fiberglass (Stratos 200) to save 0.4 g; replacing
the power connector with JST-RCY to save 1.1 g;
and removing the buck converter of 1.5 grams
using a V3 Walksnail S1 that connects directly to
the 2S rail; replace dual RF control receiver
antenna with single antenna to save 0.1 grams.
0.5-2.4-0.4-1.1-1.6-1.5-0.1=-6.6 grams
The default Specter avionics software does not include servo and PWM features, as screenshot below so, it needs software flashing.
The default Specter avionics software does not include servo and PWM features, as screenshot below so, it needs software flashing.


The default avionics software "dump all"
configuration
for the Specter is at https://drive.google.com/file/d/1NOHdJUDmjySfGR2-y1dhHfrugJVdMRq5/view?usp=sharing .
The step-up/step-down voltage regulator is
extremely light and tiny. Its input voltage range
of 3-16V is specific to Li-Ion 2-3S applications
and cannot be used in Li-Poly 4S of our current
production build.
🚨 CRITICAL DANGER:
NEVER plug a USB-C cable into the flight controller while the main drone battery is plugged in.When using this specific wiring configuration, your computer (via USB) and your external 5V regulator (via the battery) will simultaneously fight to power the exact same 5V rail. Because the standard onboard reverse-current protection diodes are bypassed in this setup, this will cause severe electrical backfeeding .
For ESC to have both connected simultaneously to check motor directions or read live sensors in Betaflight, must cut or desolder the positive (5V) red wire coming from the external regulator before plugging in the USB cable.
The 46.615g 18650 cell in the following picture weighs
47.049 g with wrap. The wrap weighs 0.418g. The
18650 cell's sticker is 0.046g. Two cells, both
without a sticker and one without wrap entirely, weigh
47.095 + 47.243 - 0.046 - 0.046 -
0.418 = 46.615 + 47.198 = 93.8g .


